RoboticsLab
Room E1.03
Brunnenlech Campus,
Tel. +49 821 5586-5073
Goals
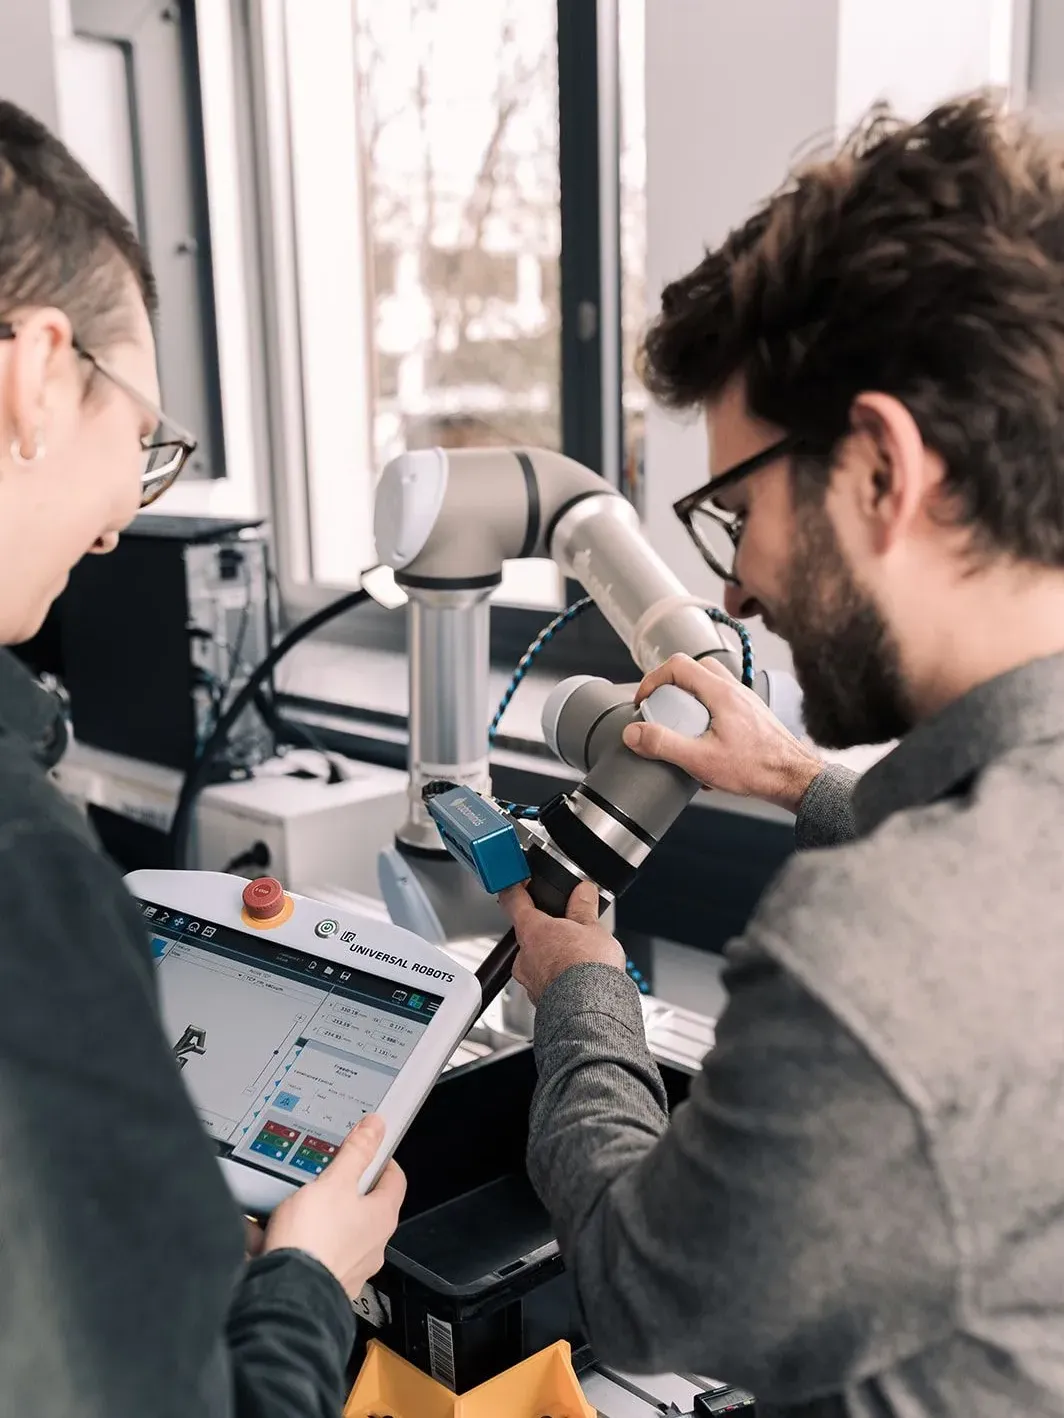
Training / Continuing Education
Training on cobot systems, AI-based control systems, and modern sensor systems
Research
- Industrial applications of lightweight robotics and AI-supported process control
- Research and development of task-oriented robot control systems
- High-frequency process analysis in robotics (big data)
We have open topics for seminar papers, theses, and research master’s theses. Please contact us if you’re interested!
Events
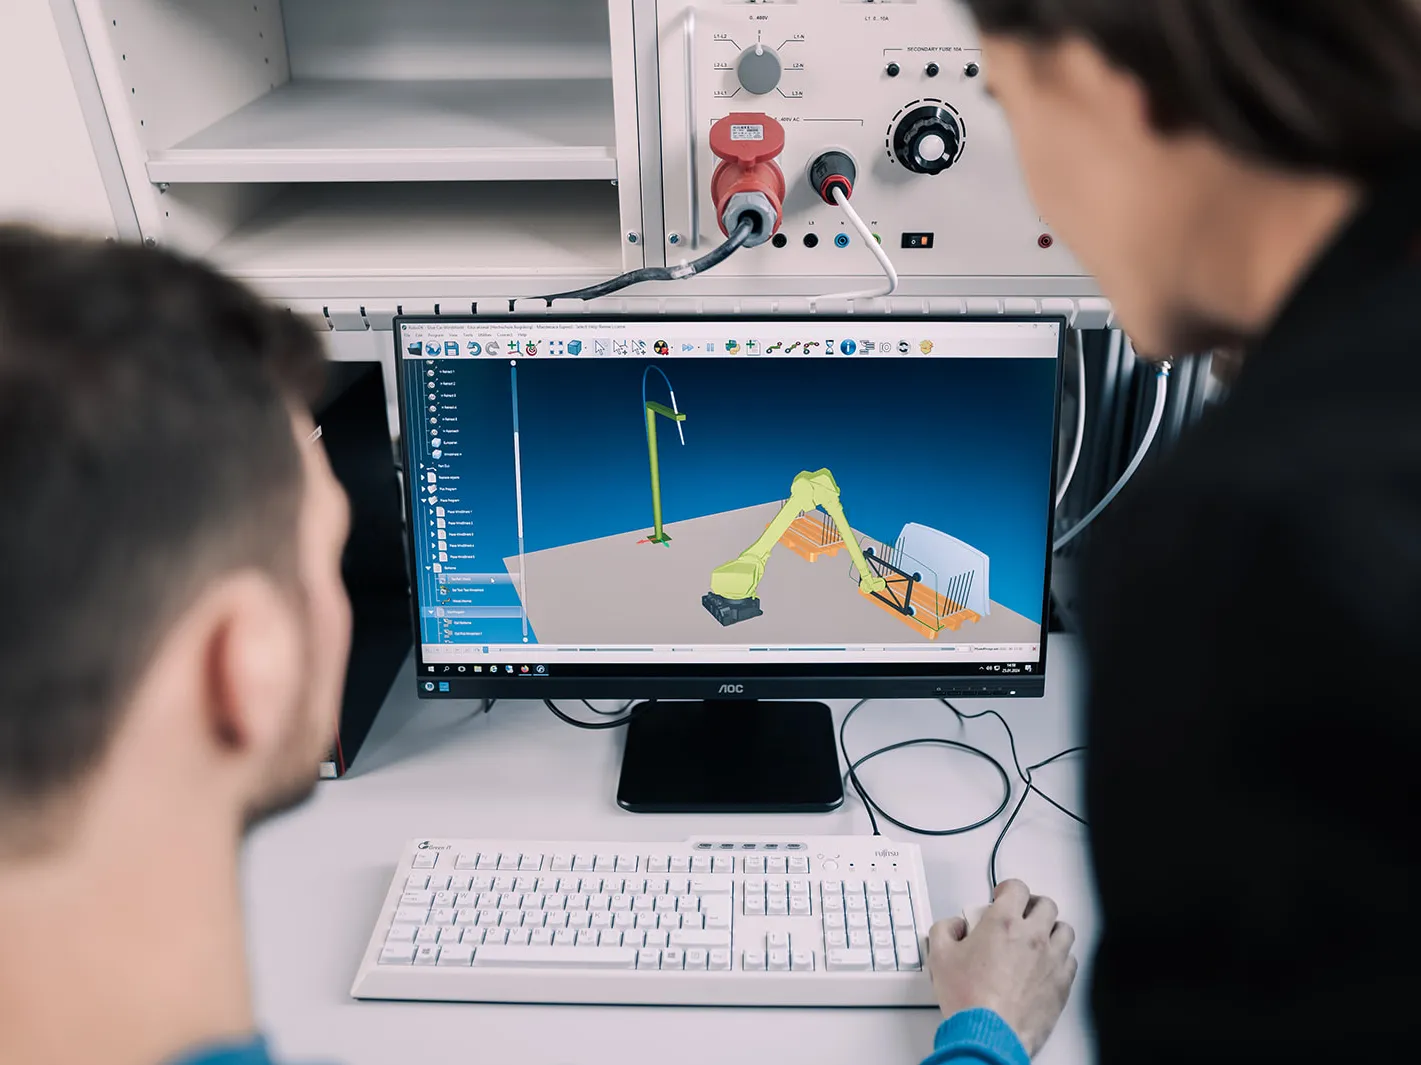
- Expert Training Courses for Cobot Applications and AI Systems
- Robotics Systems Engineering Internship
- Introductory Internship
Features
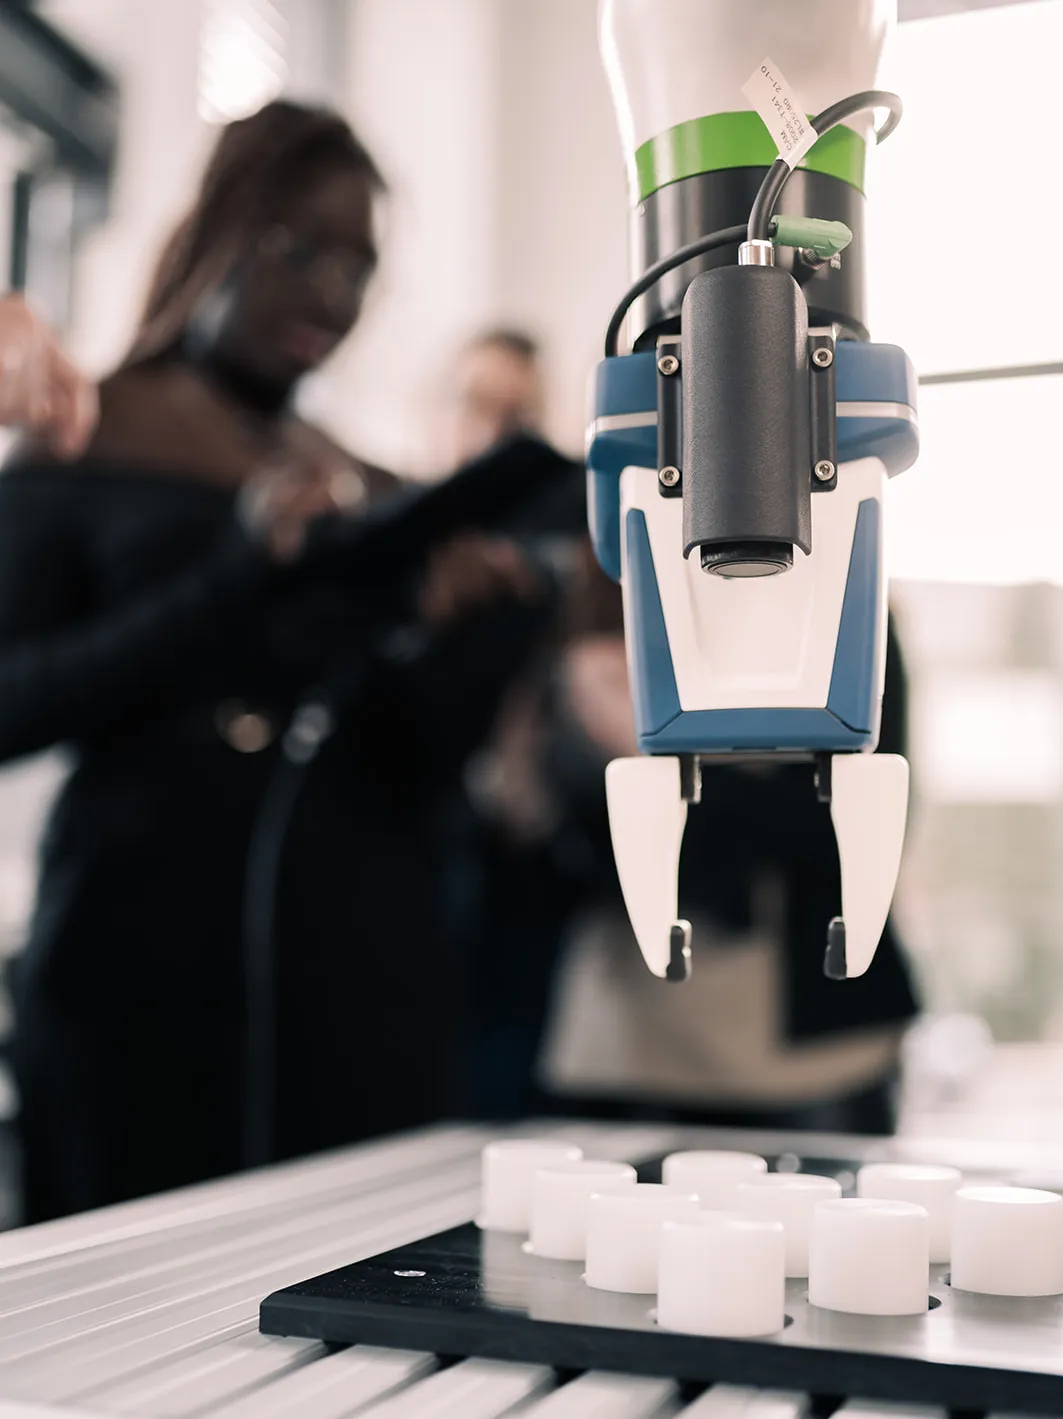
- Application Cell: AI-Assisted Robot Control (KUKA YouBot, TensorFlow, MQTT)
- Application Cell: Cobot Process (KUKA LBR iiwa 14 R820, KUKA Sunrise.OS, RoboDK)
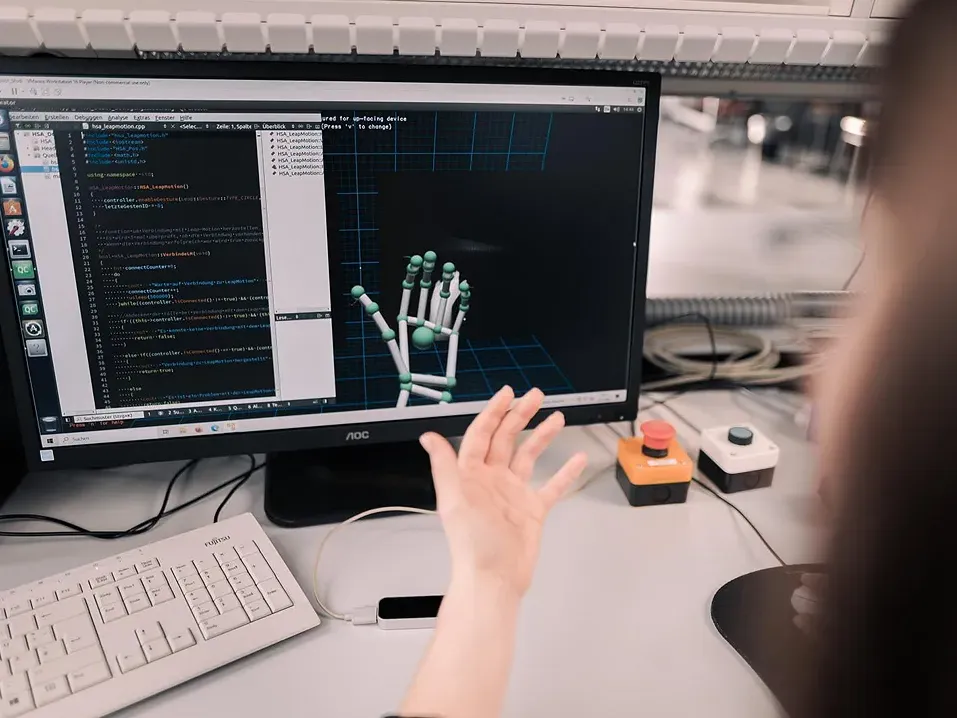
- Application Cell: Gesture-Controlled Robotics (Dobot Magician, Ultraleap Leap Motion Controller™, ROS)
- Application Cell: Cobots in Skilled Trades (Universal Robot UR10e, OnRobot Sander grinding head, OnRobot HEX-EQC 6-axis force/torque sensors, Holzkraft RLA 1101 clean-air dust collector, Sick NanoScan3 safety laser scanner)
- Application Cell: Autonomous Process Control Robotics (Universal Robot UR5e with robobrain®.vision, nanoScan3 I/O Safety Laser Scanner)
- Cobot Process Application Cell (FANUC CRX 10iA Education (Solitaire) Cell, iRVision 2D Camera Application, FANUC Roboguide)
- Agent-Based Driverless Transport Vehicle (SAFELOG AGV S2, VDA 5050-ready)
- HUMAN-ROBOT COLLABORATION (MRK) Monitoring: CoboSafe CBSF-75 force sensor for determining maximum force and clamping force
- Process Monitoring and Analysis (Non-relational Database IoTDB, Grafana)
Projects
Industry Collaboration Projects
- KIraF - AI-Based Robotic Automation for Joining Processes
- ModProFT - Model-Based Autonomous Process Planning for Functional Tests in Electronics Manufacturing
Feasibility Studies
- EvoGripper – Rethinking the Art of Gripping
- Disassembly of Battery Systems
- Precision Joining of Interlocking Components
- Offline Programming of Cobot Applications
- Monitoring high-frequency sensor data from a robotics application in an IoT database
- Contactless Trajectory Tracking for Collaborative Robots
Photos from RoboticsLab


Guidelines for Behavior in the Robotics Lab
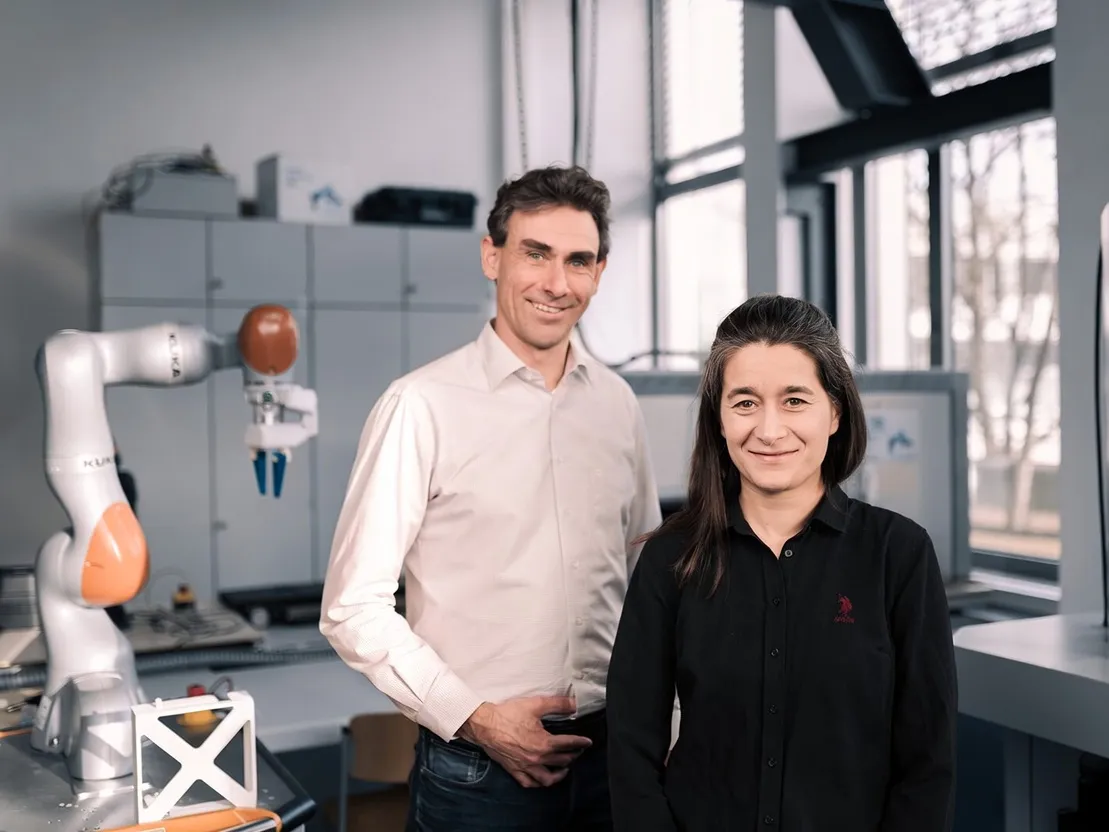
Team
The RoboticsLab team: Lab Director Prof. Dr.-Ing. Simon Dietrich and Lab Engineer Emel Cetin-Balk